InOrbit.AI Releases OpenRobOps ISO 21423 Reference Implementation
InOrbit.AI open-sourced OpenRobOps, a system for orchestrating and managing mobile robot fleets, under the Apache 2.0 license. It is the first reference implementation of the ISO 21423 standard for data exchange between robots and fleet management systems.
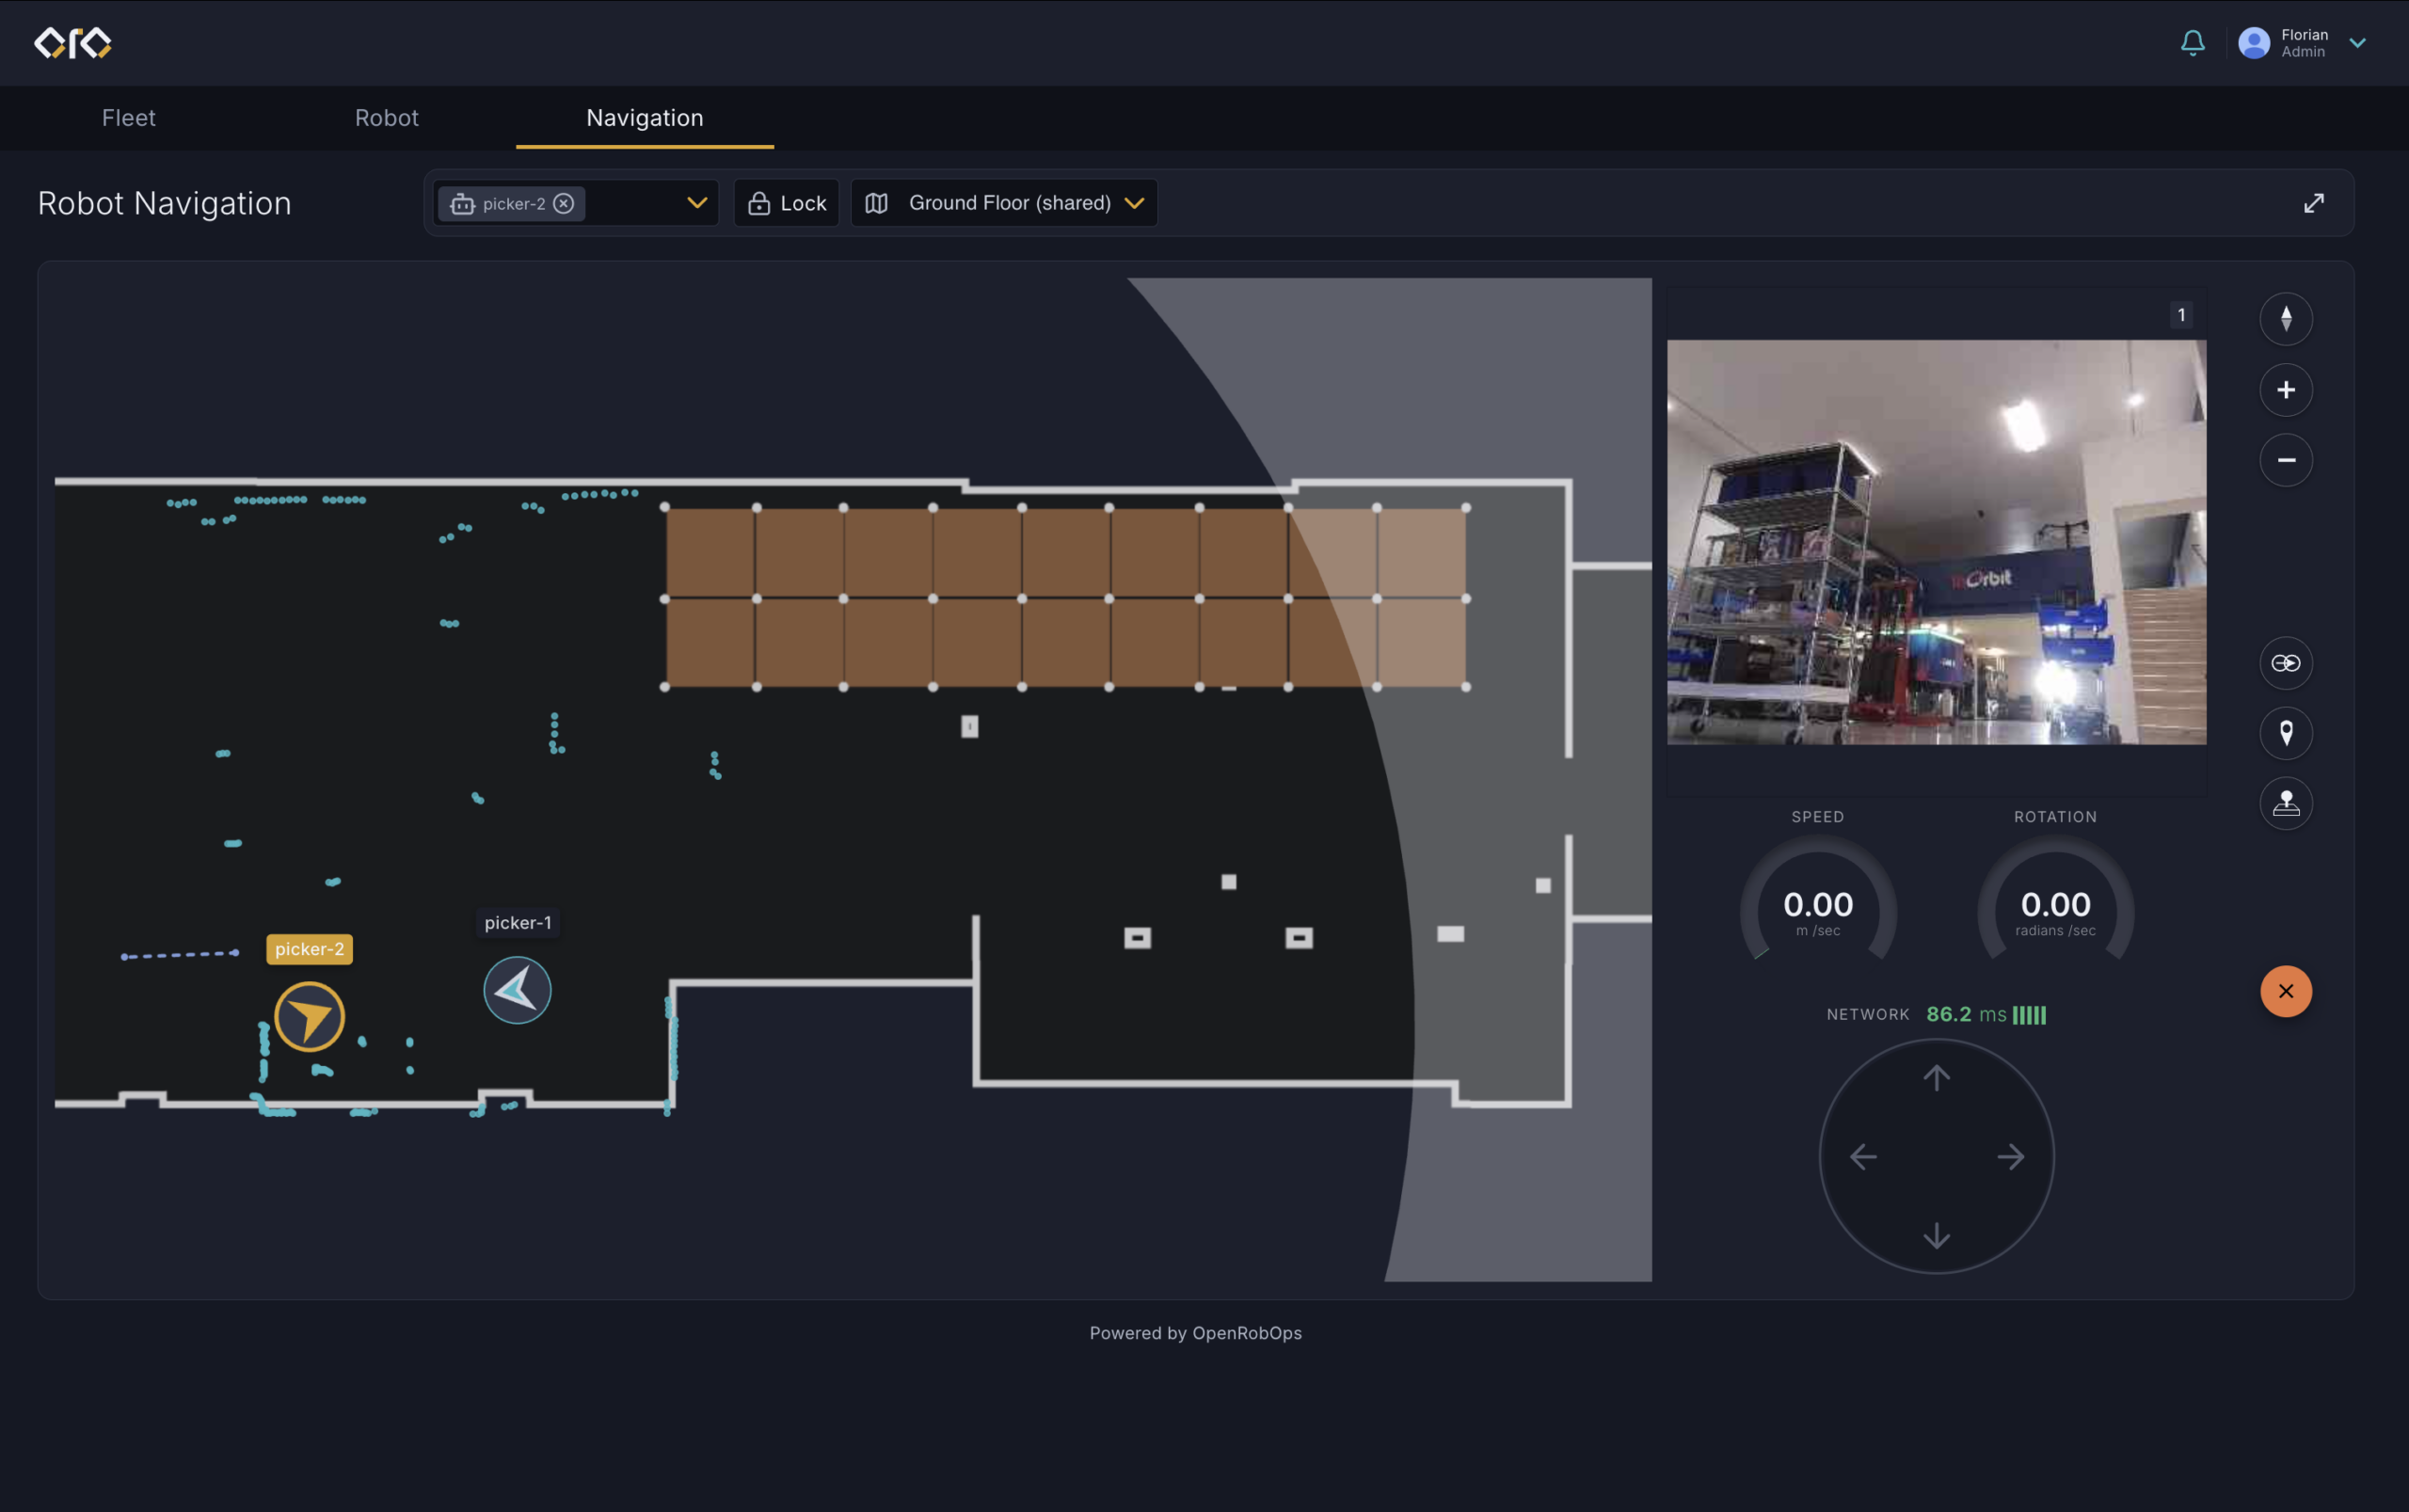
- OpenRobOps is Apache 2.0 licensed with no royalties
- First reference implementation of ISO 21423 for industrial mobile robots
- Supports Open-RMF, telemetry, spatial tracking and configuration as code
- Works with any robots: wheeled, bipedal and quadrupedal
Read next
Software