RoboParty open-sources its RP1 humanoid robot full stack
RoboParty has released RP1, a 135 cm humanoid robot, as a fully open-source full-stack platform covering mechanical and electrical design, its ROMOMO joint modules, firmware and control software. The open version has 24 degrees of freedom and the Pro version 30, with joint torque of 25–160 Nm at 48V and CAN-FD. A beta program for developers is open for applications.
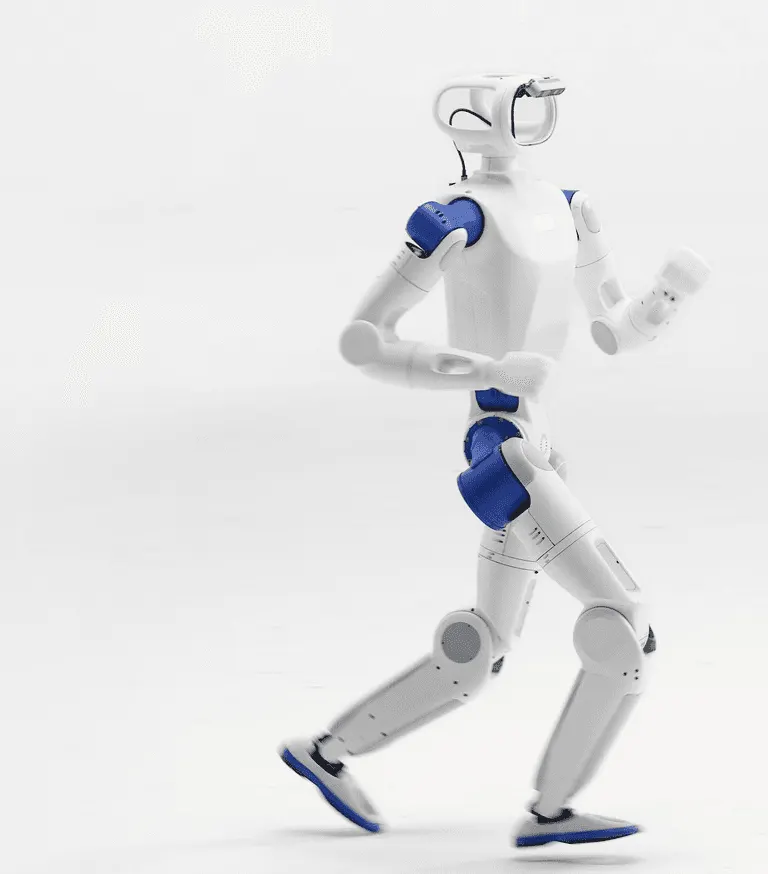
- RP1 stands 135 cm tall with 24 DoF in the open version and 30 in Pro
- ROMOMO joints deliver 25–160 Nm at 48V over CAN-FD
- Control runs at 500Hz with policy updates at 50Hz
- GitHub hosts CAD, schematics, Gerber files, BOM and URDF/MJCF models
Read next
Hardware