ETH Zurich Robotic Hand Walks, Steers, and Presses Keys on Its Own Fingers
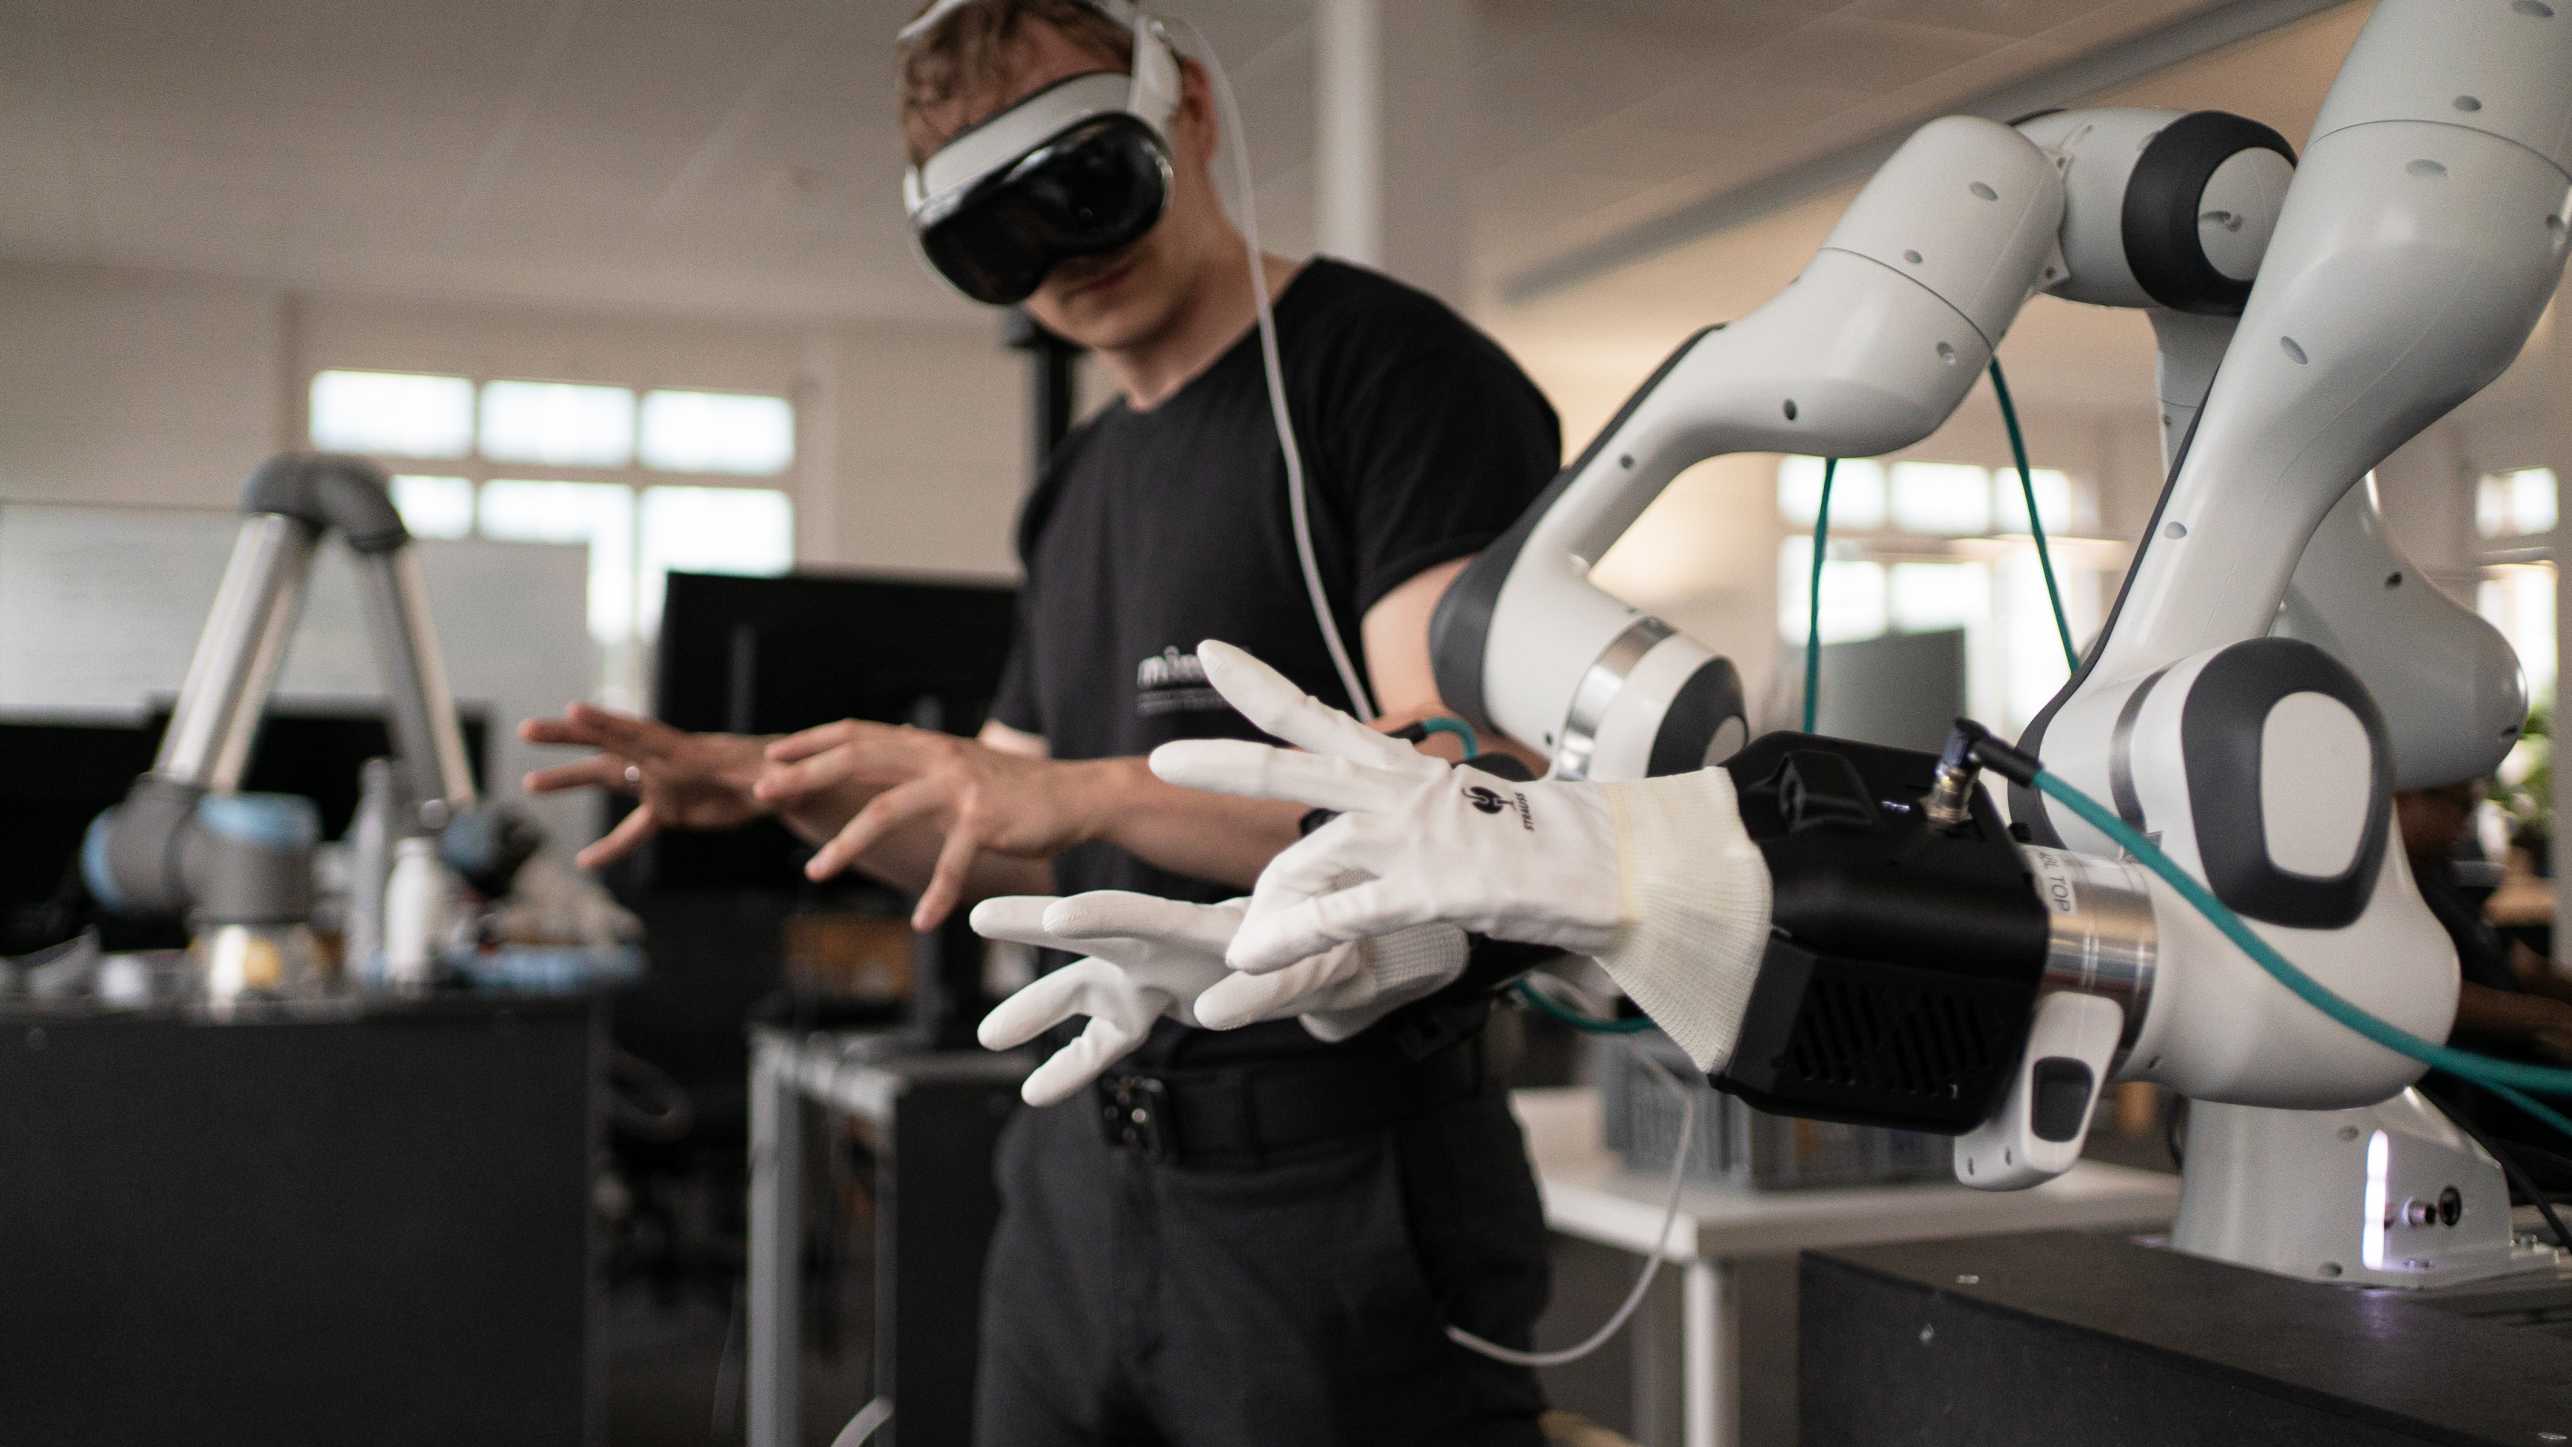
ETH Zurich's Soft Robotics Lab trained a five-fingered robotic hand to move across 14 surface types, get up after falls, steer using onboard sensors, and press keys by supporting its weight on its own fingers. Training was done in simulation via reinforcement learning, with no separate locomotion mechanism needed.
- Hand crawls on 14 surface types without separate walking drive
- System gets up after falls and steers via onboard sensors
- Fingers support hand's weight when pressing keys
- Behavior trained in simulation via reinforcement learning
Read next
Hardware