BeetleBot robot uses artificial muscles and two-way feedback
A KAIST team built BeetleBot, a beetle-inspired robot with 3D-printed liquid crystal elastomer muscles that contract 45% when heated to 110 °C. It is controlled by a flexible finger-worn sensor and uses a camera for bidirectional feedback between operator and robot.
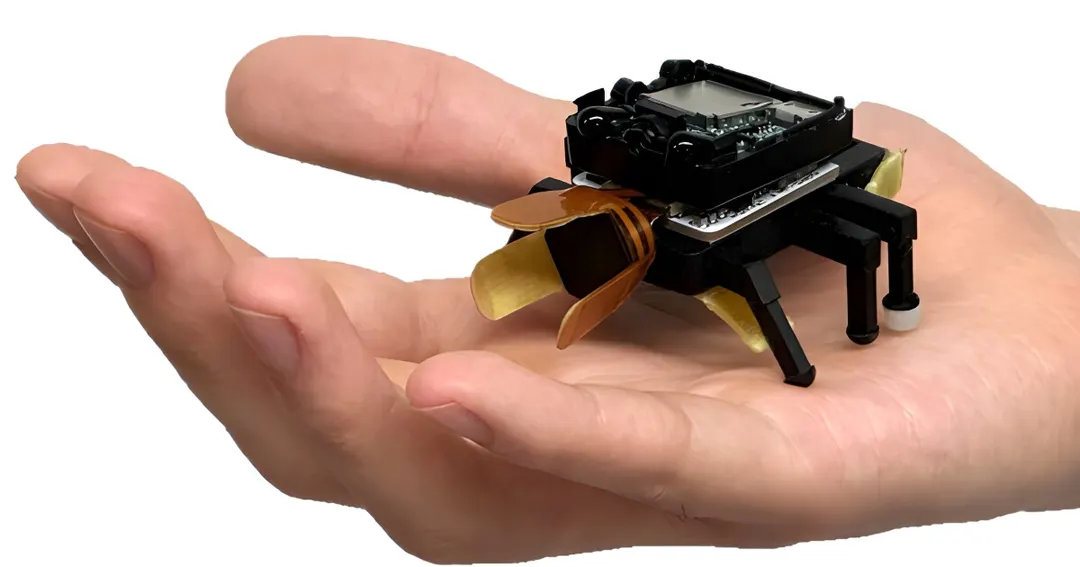
- LCE muscles contract 45% when heated to 110 °C by current
- Control comes from a flexible finger patch with four commands
- Gripper mimics beetle mandibles and includes a pressure sensor
- In tests it navigated turns, gripped an object and moved it
Read next
Hardware