OpenArm 2.0: open-source 7-DOF robot arm with QDD joints and in-hand camera
Tokyo-based Enactic unveiled OpenArm 2.0, an open-source 7-DOF robot arm for physical AI research and teleoperation. Quasi-direct-drive backdrivable joints enable bilateral force feedback, with 4.1 kg nominal and 6 kg peak payload, 606 mm reach and 1 kHz CAN-FD control. The ecosystem includes the OpenArm Cell test rig and the motorless KER replica.
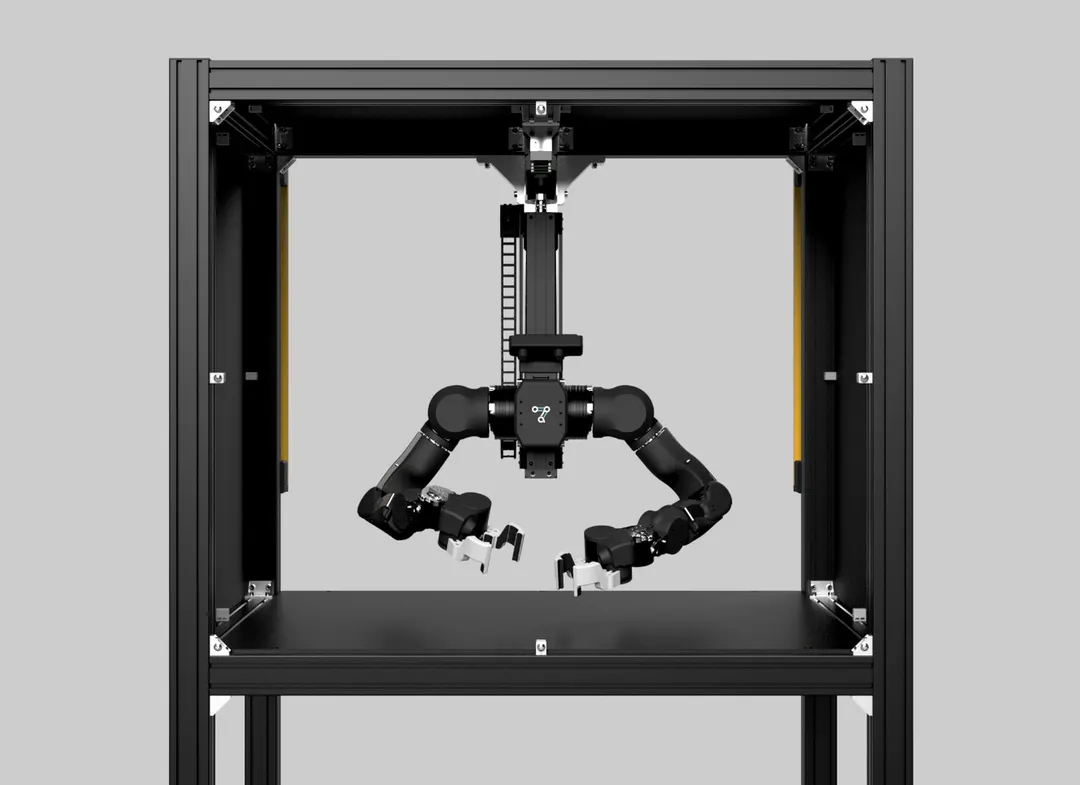
- 7 axes plus a parallel gripper with 88 mm jaw opening and RGB camera
- Nominal payload 4.1 kg, peak 6 kg, reach 606 mm
- CAN-FD: 1 Mbps nominal, 5 Mbps data, 1 kHz control loop
- Open CAD, BOM, firmware, ROS 2, MuJoCo and Isaac Lab support
Read next
Hardware