CARL framework improves robot trajectory tracking by up to 15%
Researchers at the University of Illinois Urbana-Champaign developed contraction-aware reinforcement learning (CARL), which combines reinforcement learning with contraction theory to guarantee stability. Tests on a wheeled TurboBot 3 Burger, a flapping drone and a six-legged Jethexa showed up to 15% better trajectory tracking in simulation and on real hardware. The code is open-sourced on GitHub.
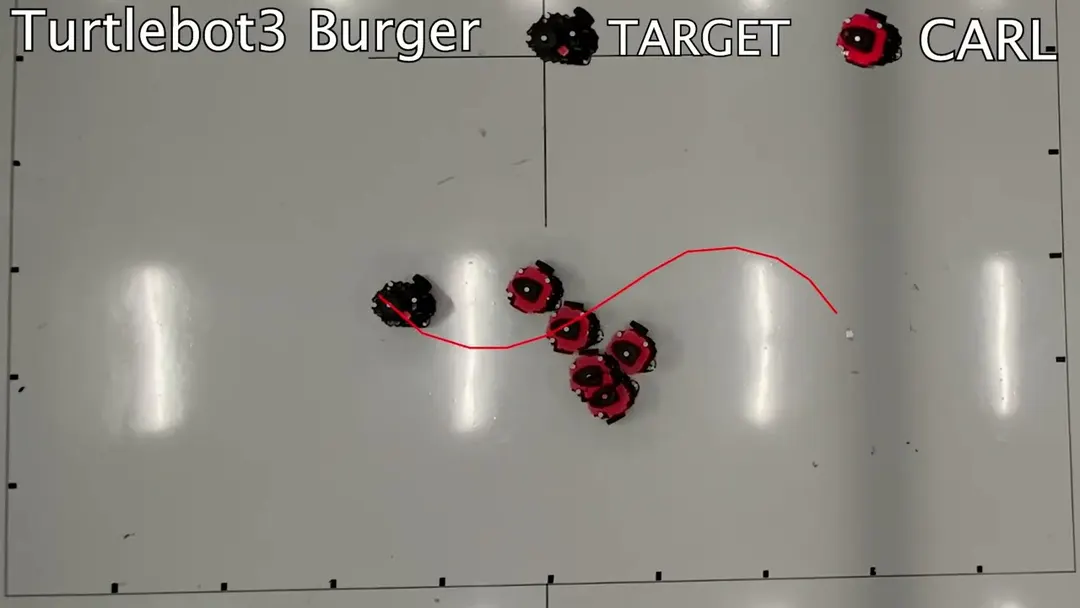
- CARL improves tracking accuracy by up to 15% across three robot types
- Method combines reinforcement learning with contraction theory
- Validated in simulation and on physical robots
- Implementation code published on GitHub
Read next
Policy