MIT's SANDO drone planner guarantees collision avoidance without a prior map
MIT's SANDO navigation system builds a safe flight corridor around the possible future positions of moving hazards, offering a mathematical guarantee of collision avoidance without a prior map. The planner only needs an upper bound on obstacle speed. In simulations it reached destinations faster than state-of-the-art systems while avoiding collisions, and a real drone completed 12 flights without hitting moving obstacles.
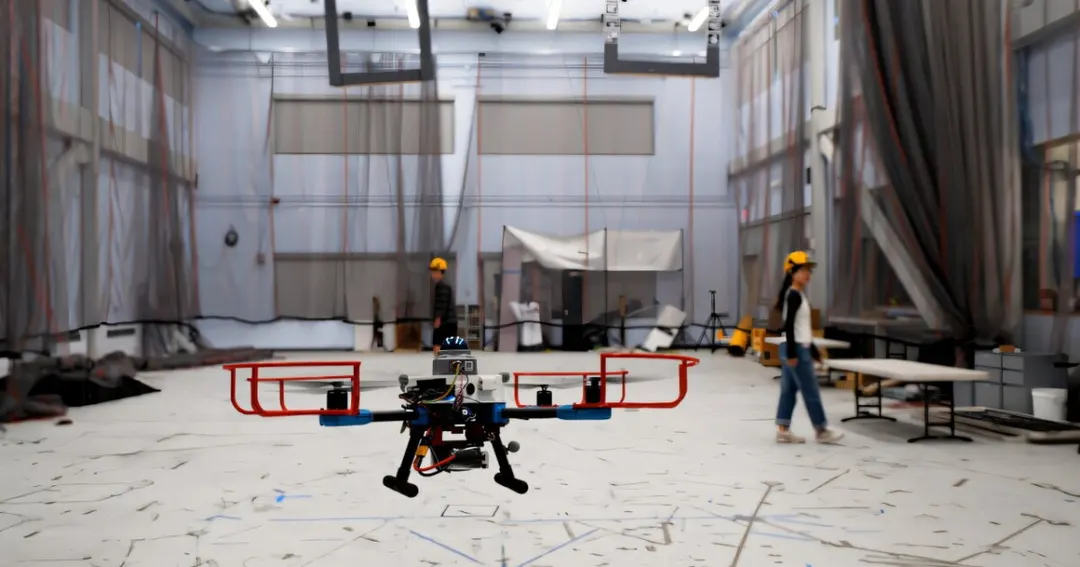
- SANDO needs no map or obstacle trajectories, only their top speed
- Each obstacle is wrapped in a virtual sphere that grows over time
- In simulations it beat comparable planners on speed with zero collisions
- A real drone flew 12 flights avoiding all moving obstacles
Read next
Hardware